

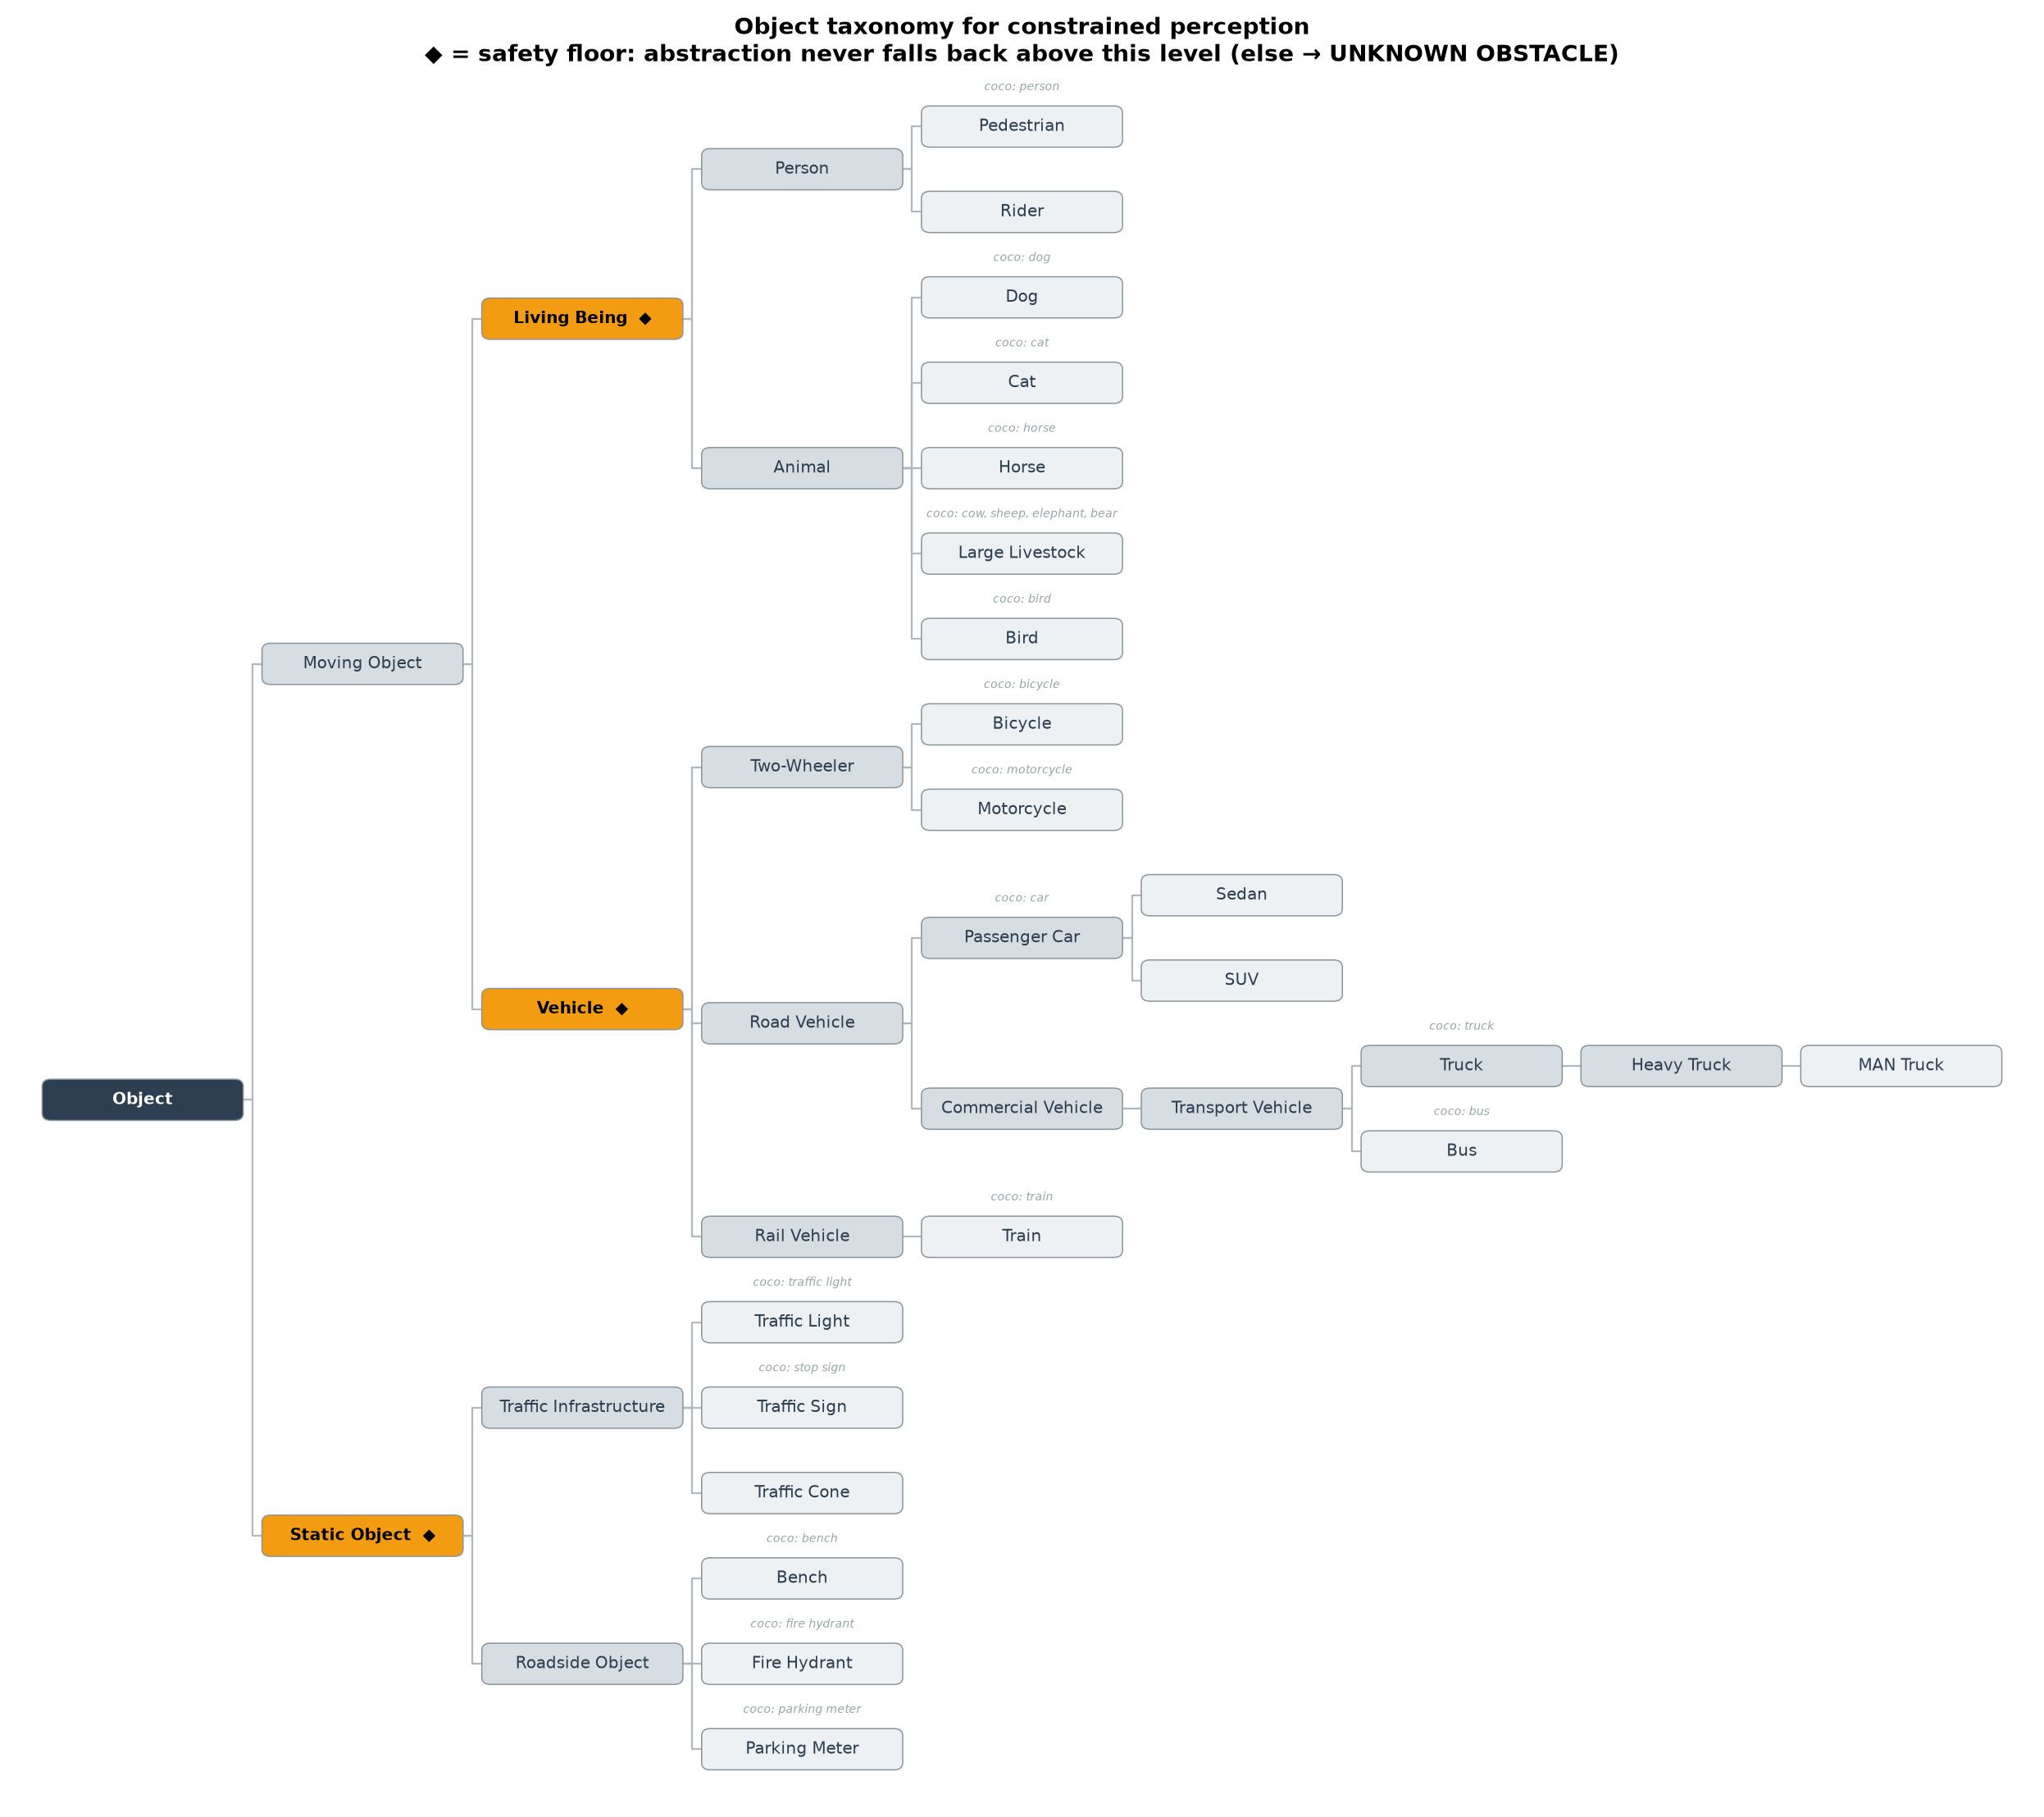
Living Being, with the full taxonomy descent path and an independent segmentation cross-check shown alongside.
## Watch the 3-minute explainer
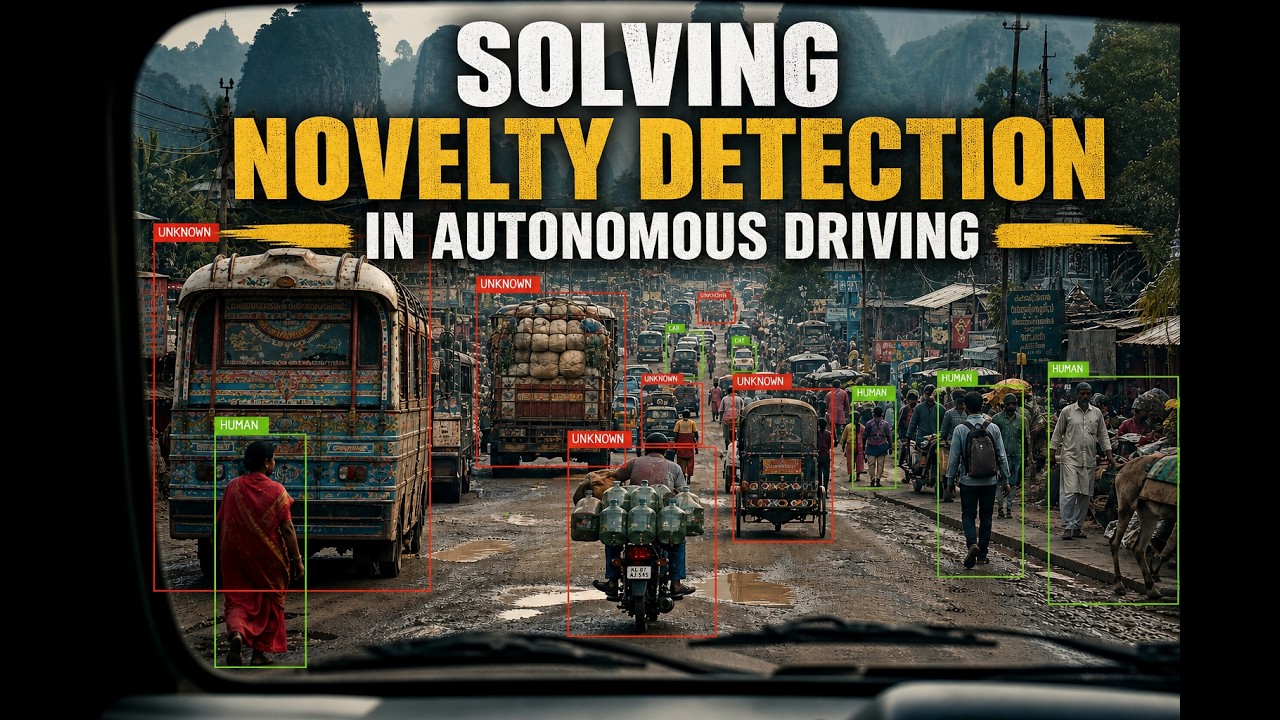
 ## How it decides (worked examples)
Each detection produces a decision path: probability mass per node, the safety floor, and the resulting action.
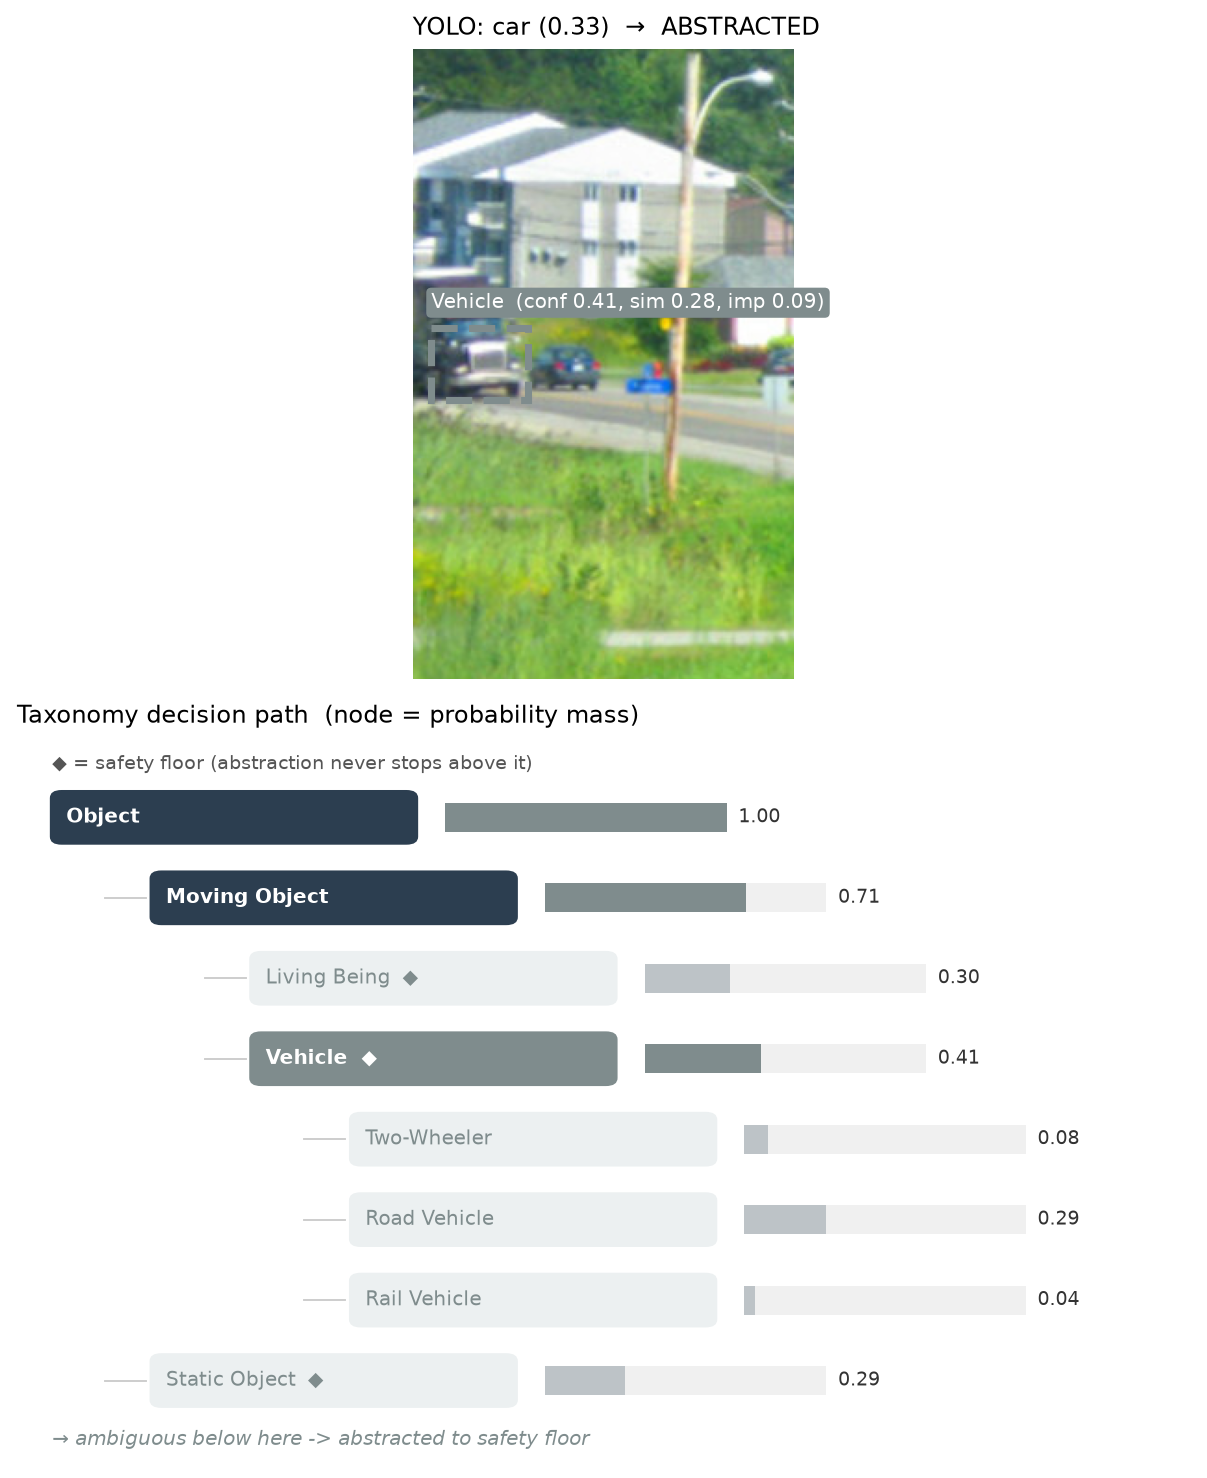
ABSTRACTED. YOLO calls a distant truck "car" (0.33). The mass is ambiguous below the Vehicle floor, so HOWC does not guess a leaf: it reports Vehicle, still useful, never wrong.
|
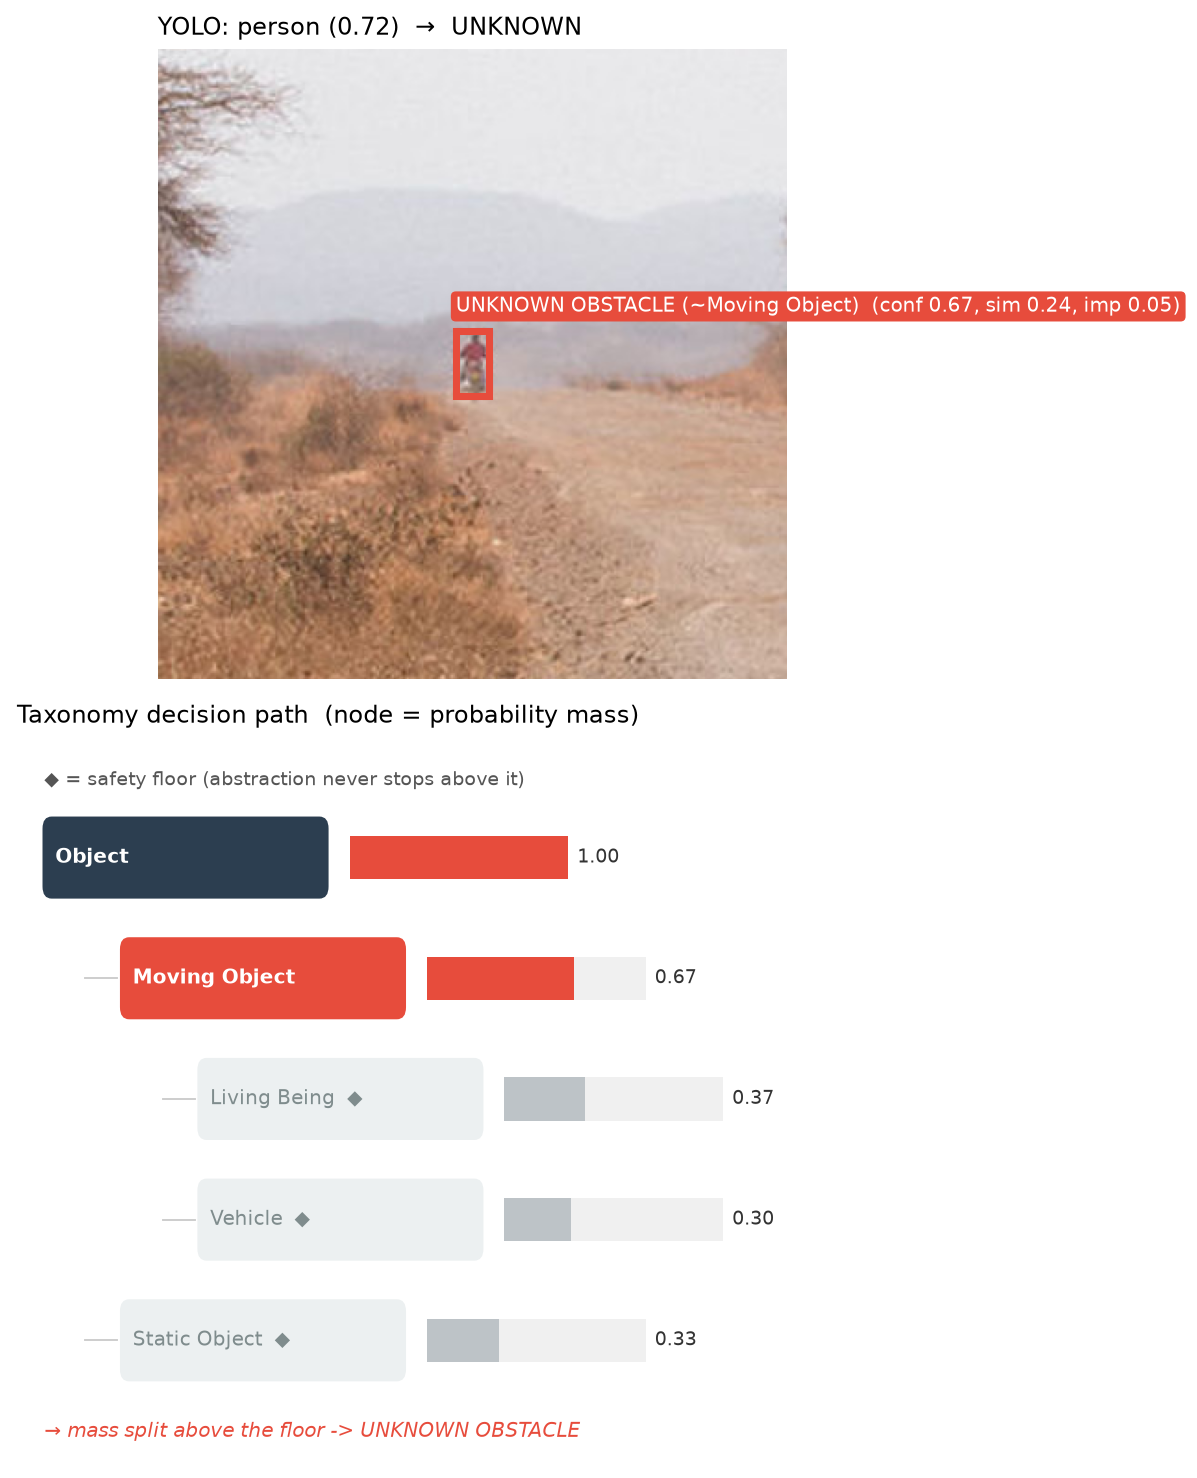
UNKNOWN. A rural-road anomaly YOLO calls "person" (0.72). The mass splits above the floor across Living Being / Vehicle / Static, so HOWC refuses a category and flags UNKNOWN OBSTACLE. |
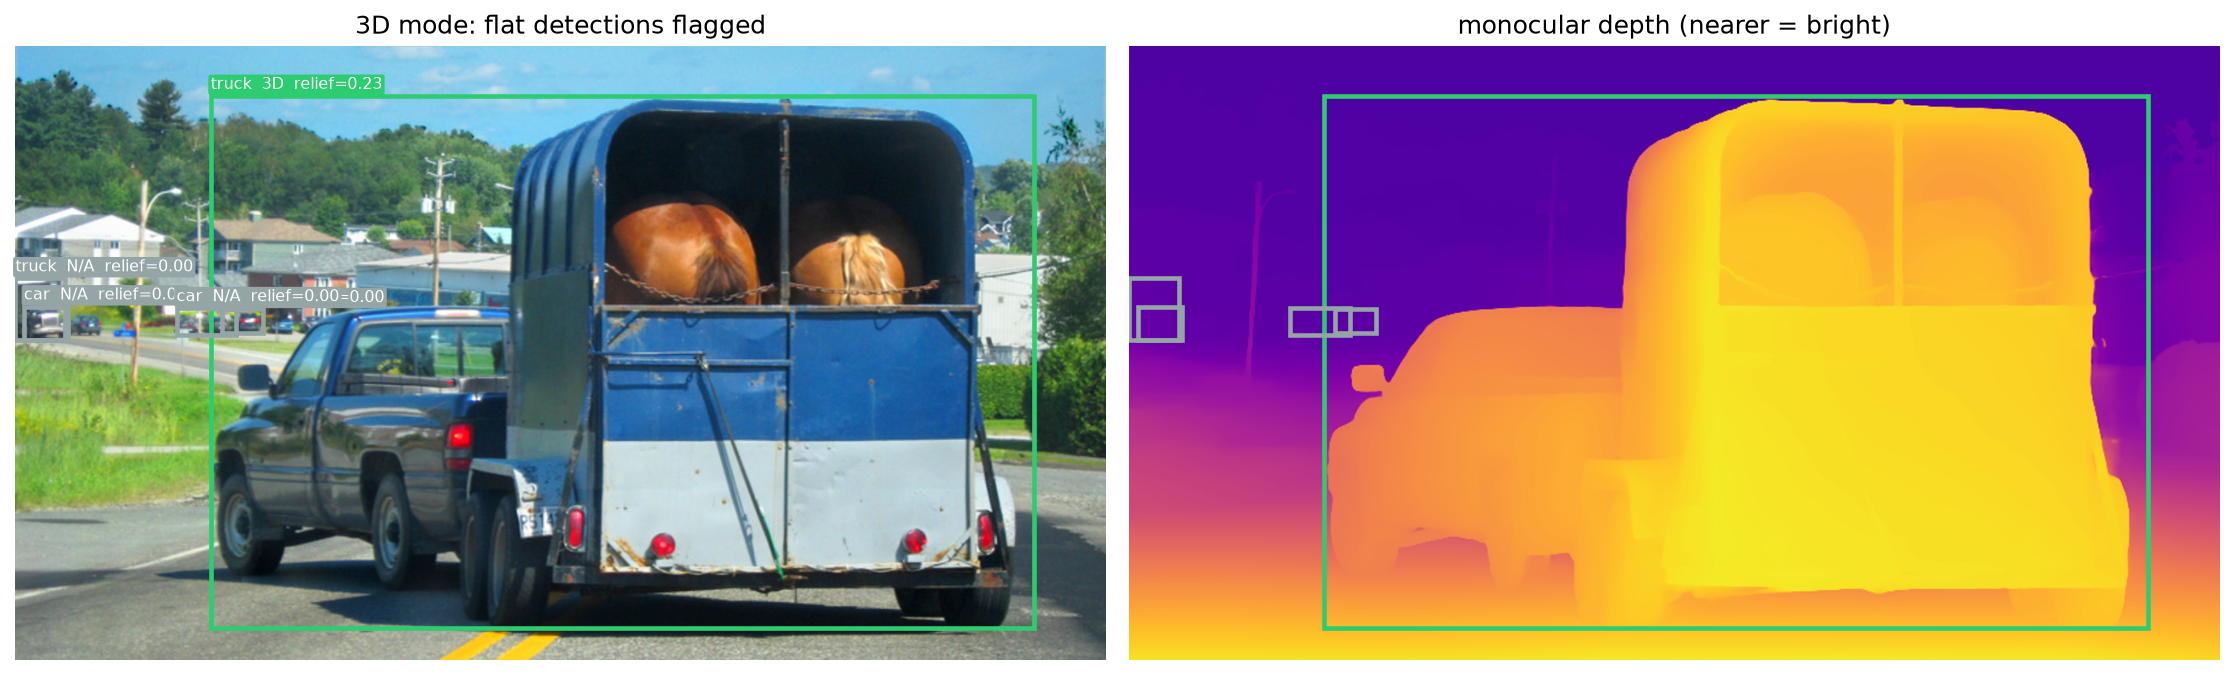 Left: 3D mode flags flat detections. Right: the monocular depth field (nearer = bright). This is a feasibility signal, not a solved module, and the paper is explicit that no single 2D cue suffices.
## Results (honest)
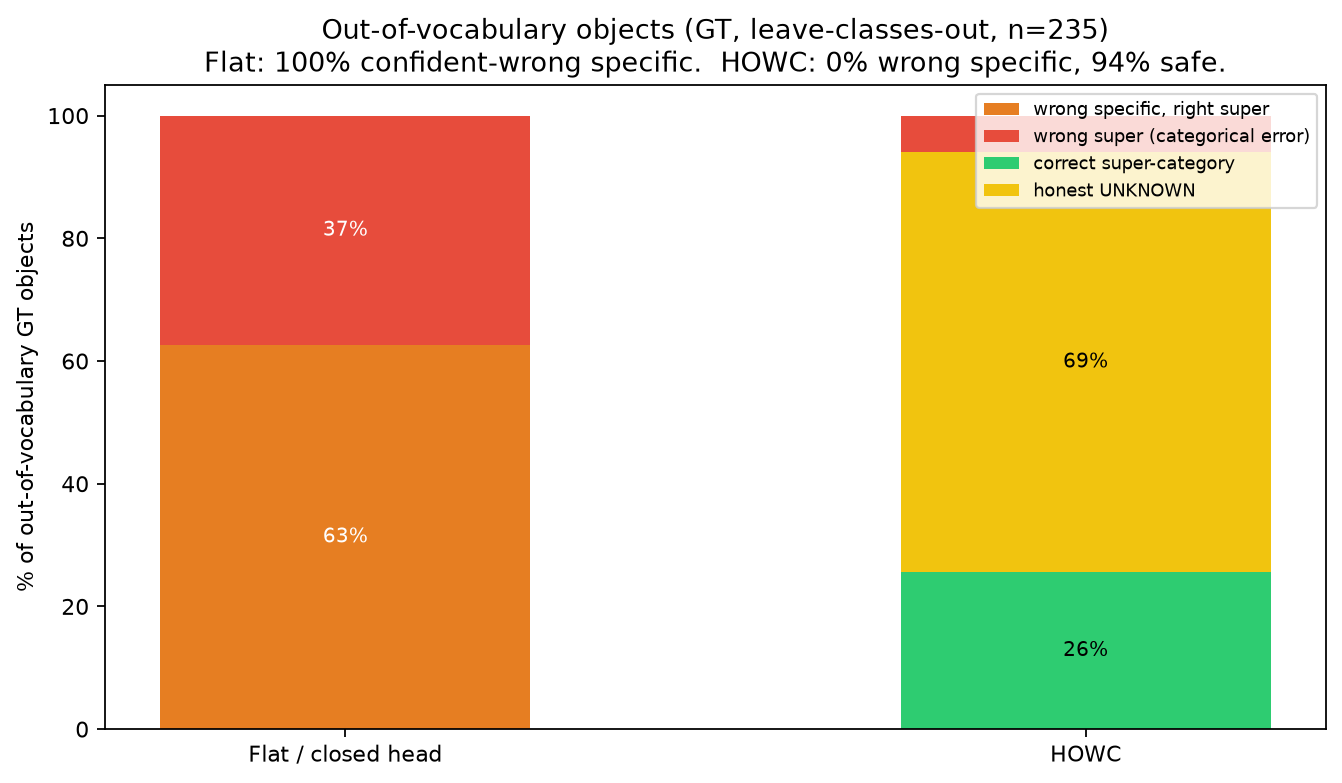
**Out-of-vocabulary objects** (v3 ground-truth leave-classes-out on COCO, n=235). Hold seven classes out of the taxonomy, then classify their real annotated crops:
 | On out-of-vocabulary objects | Flat / closed head | **HOWC** |
|---|---|---|
| Confident **wrong** specific label | **100%** | **0%** |
| ... of which in the **wrong super-category** | 37% | 0% |
| Safely handled (right super-cat, or honest UNKNOWN) | 0% | **94%** |
| Correct super-category recovered | — | 26% |
| Conservatively flagged UNKNOWN | — | 69% |
On **known, in-taxonomy** objects: **0% off-branch (categorical) errors** with ~24% calibrated abstention, versus a flat arg-max head's ~53% off-branch errors.
The safety/specificity trade-off is a dial, not a fixed point. Every hierarchical configuration stays **100% safe on novel objects** while still usefully classifying up to 76% of known ones; the flat baseline sits alone at 0% novel-safe.
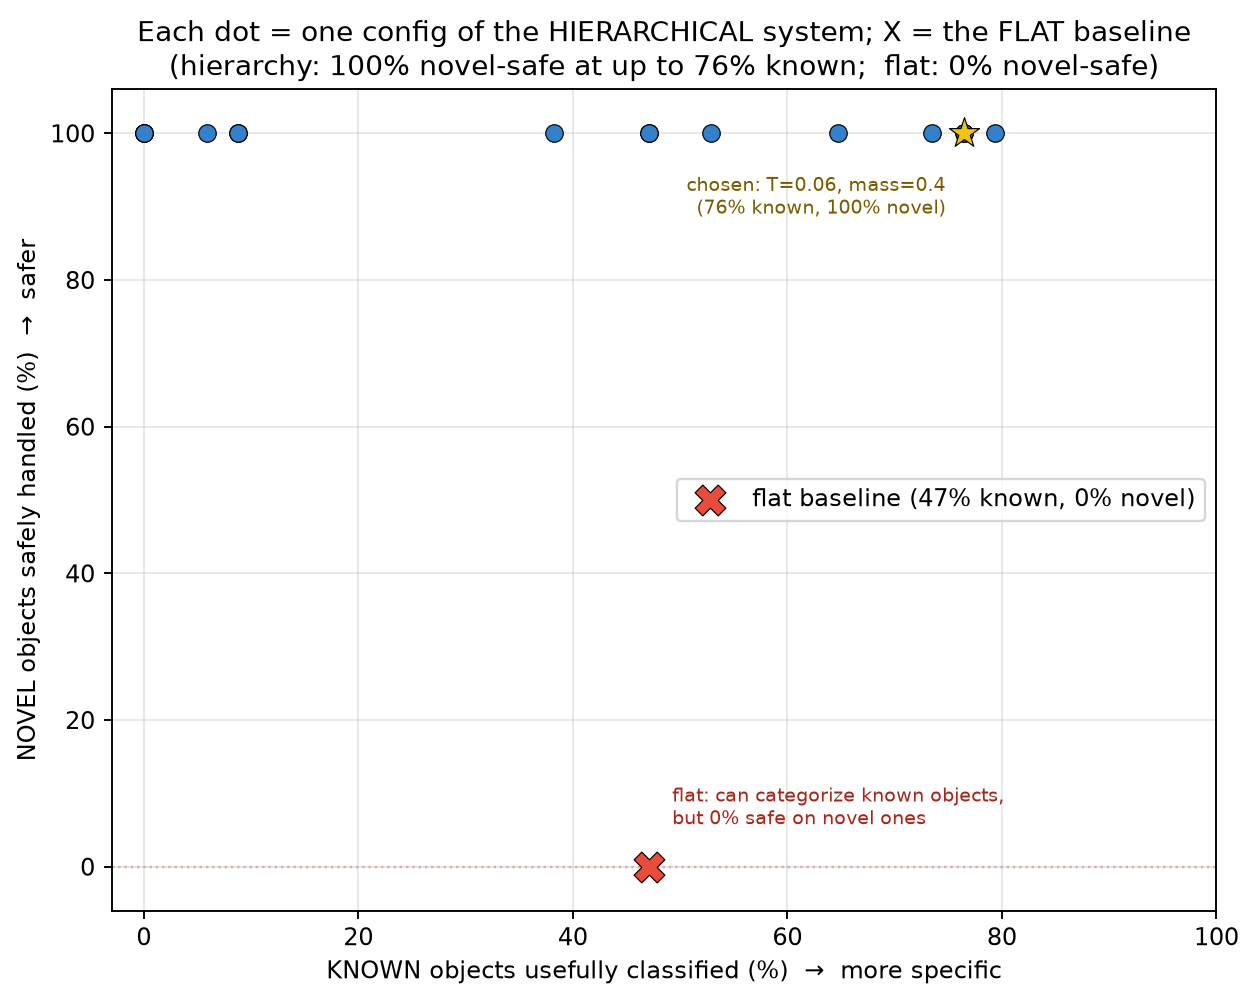 > **What this is, and is not.** This is a **safety** result, not a specificity one. On closed-set COCO mAP a trained YOLO is more accurate, and we say so. The contribution is the abstraction layer over open-vocabulary (CLIP) features: it never makes a confident categorical mistake on an unknown object, at the honest cost of 69% abstention. The point is the tail, not the leaderboard.
## An independent second path
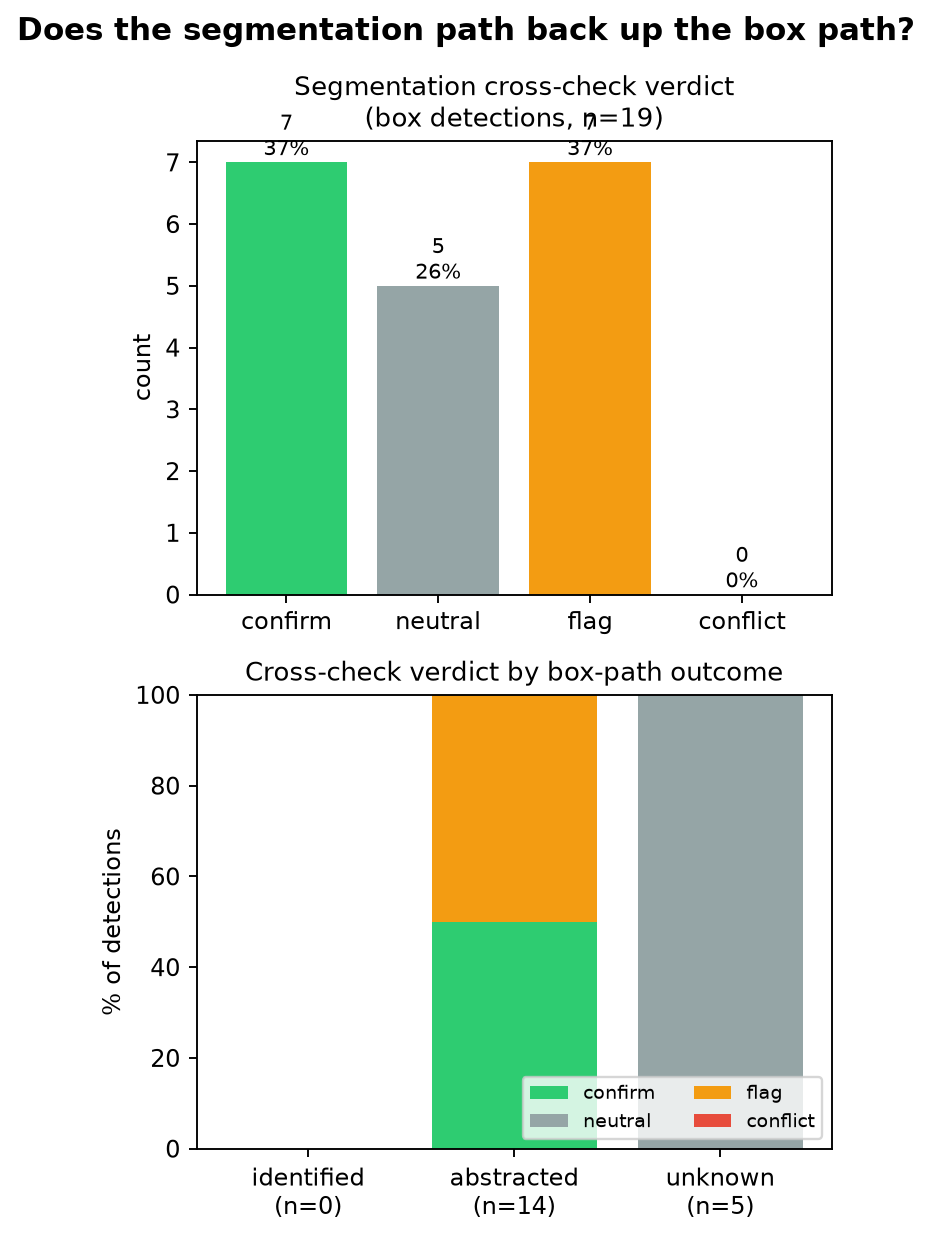
The box classification is cross-checked against a class-agnostic **segmentation** path: does the pixel evidence back up the box verdict? Across sampled detections it **confirms or stays neutral 63%** of the time and **flags 37%** for review, with **0% hard conflicts**, and it agrees most where it should (on abstracted and unknown objects).
 ## Run it locally
Self-contained: code + taxonomy + a Gradio app. Training-free (pretrained YOLO + CLIP zero-shot); first run downloads weights (~360 MB).
```bash
pip install -r requirements.txt
python app.py # Gradio UI: upload an image, see the taxonomy decision path
python app.py --share # same, but also prints a temporary public URL (~72h)
```
## Papers
- **Open-world (v3):** *Open-World Hierarchical Perception: Taxonomic Abstraction over Class-Agnostic Proposals for the Safe Handling of Out-of-Vocabulary Road Objects*, F. Schaller, [arXiv:2608.07577](https://arxiv.org/abs/2608.07577).
- **Foundational (v1):** *Hierarchical Taxonomic Abstraction for the Safe Handling of Novel Objects in Autonomous Driving Perception*, [doi:10.5281/zenodo.21593472](https://doi.org/10.5281/zenodo.21593472).
- **Source & full history:**